www.ptreview.co.uk
15
'26
Written on Modified on
Universal Robots Launches Gen 7 Industrial Robotics Platform
Gen 7 is a seventh-generation collaborative robot platform featuring reengineered controllers, AI-ready tool flanges, and the PolyScope X operating system.
www.universal-robots.com
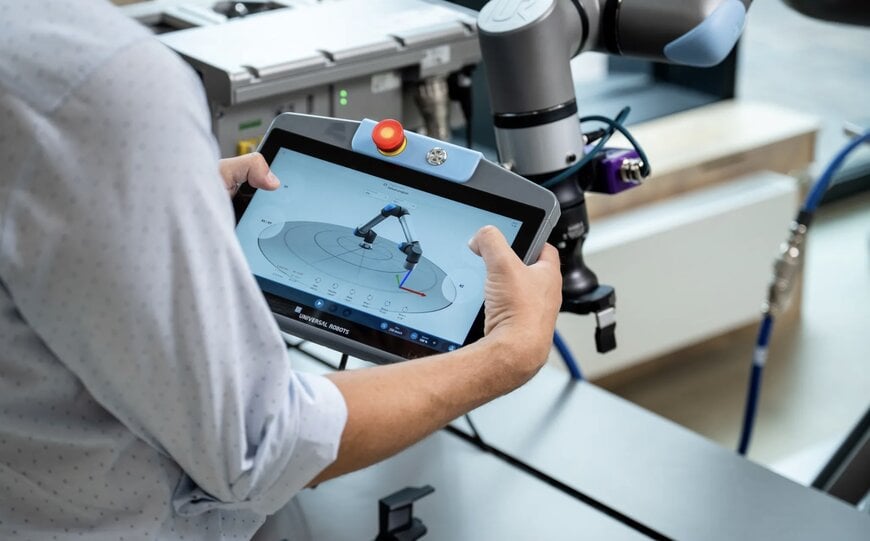
Universal Robots has unveiled Gen 7, its seventh-generation robotics architecture designed to deploy artificial intelligence and physical automation into factory production environments. Anchored by the PolyScope X operating system, the platform incorporates an end-to-end redesign encompassing new robot arms, a reengineered control cabinet, an ergonomic teach pendant, and an integrated tool flange interface.
g-Series Manipulators and AI Flange Architecture
The platform introduces three manipulators designated as the g-Series: the UR10g-1750, UR17g-1300, and UR18g-950, with designations corresponding to payload capacity in kilograms and reach in millimeters. The arms integrate an AI-ready tool flange that routes power, data pipelines, and safety circuits directly to the tool center point, eliminating external cable routing to support cameras, high-bandwidth sensors, and end-effectors.
Integrated six-axis force-torque sensing, compliance impedance control, and Real-Time Data Exchange (RTDE) provide contact sensing to support precision physical AI applications, including dexterous component manipulation and force-sensitive assembly tasks.
Controller Performance and Programming Interfaces
Computing execution is driven by the CB7 Core controller, which delivers 40% more processing capability in a 30% smaller footprint compared to prior hardware revisions. The controller supports multi-network switching to interface directly with programmable logic controllers (PLCs), human-machine interfaces (HMIs), manufacturing execution systems (MES), industrial PCs (IPCs), and machine vision systems. The CB7 Core is available in standalone and cabinet-mountable compact formats and maintains backwards hardware compatibility with existing e-Series and UR Series arms.
Operating software is centered on PolyScope X, which incorporates ROS2 communication nodes, open APIs, ISO 10218-1 safety integration, and support for third-party extensions including ProfiSafe and OPC UA. Handheld parameterization uses the TP7 Core teach pendant, which is more than 20% lighter than predecessor units and features a full HD touchscreen, ergonomic multi-grip contours, user-configurable smart buttons, and a virtual jog stick.
Direct teaching at the tool tip is managed through the SP7 Smart Panel, an interface mounted at the tool flange featuring safety-rated freedrive actuation, visual status LEDs, and three assignable input buttons configured to trigger PolyScope X Smart Skills without requiring teach pendant interaction.
Safety Architecture and Cybersecurity Certification
System safety meets Performance Level d (PLd), Category 3 functional safety certification in accordance with ISO 13849-1. The g-Series arms hold TÜV certifications against ISO 10218-1 standards and UL 1740 specifications. Teradyne Robotics maintains cybersecurity compliance certified to IEC 62443-4-1 Maturity Level 3 (ML3), covering secure software development lifecycles across embedded and edge-level software releases.
Additional Context
This section details technical specifications and competitive benchmarking not included in the original news release.
Standard collaborative robots route camera power and vision lines through external corrugated conduits along arm links, creating mechanical snag risks and limiting continuous wrist rotation during complex manipulation. Routing high-speed data, power, and safety circuits internally through slip rings directly to the tool flange eliminates external harness wear and snag points during rapid motion cycles.
Additionally, conventional controllers rely on closed, proprietary architectures that require protocol gateways to interface with external processors. Incorporating native Robot Operating System 2 (ROS2) support and high-speed data streaming removes hardware conversion layers, reducing communication latency between external artificial intelligence models and low-level servo drives for responsive visual-servoing and force adjustments.
Edited by Romila DSilva, Induportals Editor, with AI assistance.
www.universal-robots.com